byte robotics combines robotics engineering with proprietary optimization software. We analyze motion sequences, develop well-founded improvements and support implementation where required.

Many robot cells have untapped potential in their motion paths, process sequences and waiting times. We identify that potential, develop suitable improvements and compare them transparently with the baseline.
A structured optimization project combines engineering analysis, software-assisted exploration and validation against real process constraints.
Provide the robot cell, existing programs, process requirements and the objective of the optimization. Together, these inputs define the engineering task.
Our software supports the search for feasible motion and alternative sequences while accounting for the agreed geometry and process constraints.
Our engineers assess the alternatives in the context of the complete process and select changes that are technically sound and practical to implement.
The agreed result is documented, transferred into the relevant workflow and validated in simulation or on the physical cell as required.
Our team brings together robotics research, software development and industrial engineering. Founded on research in Magdeburg, byte robotics makes automated motion planning part of established engineering workflows.
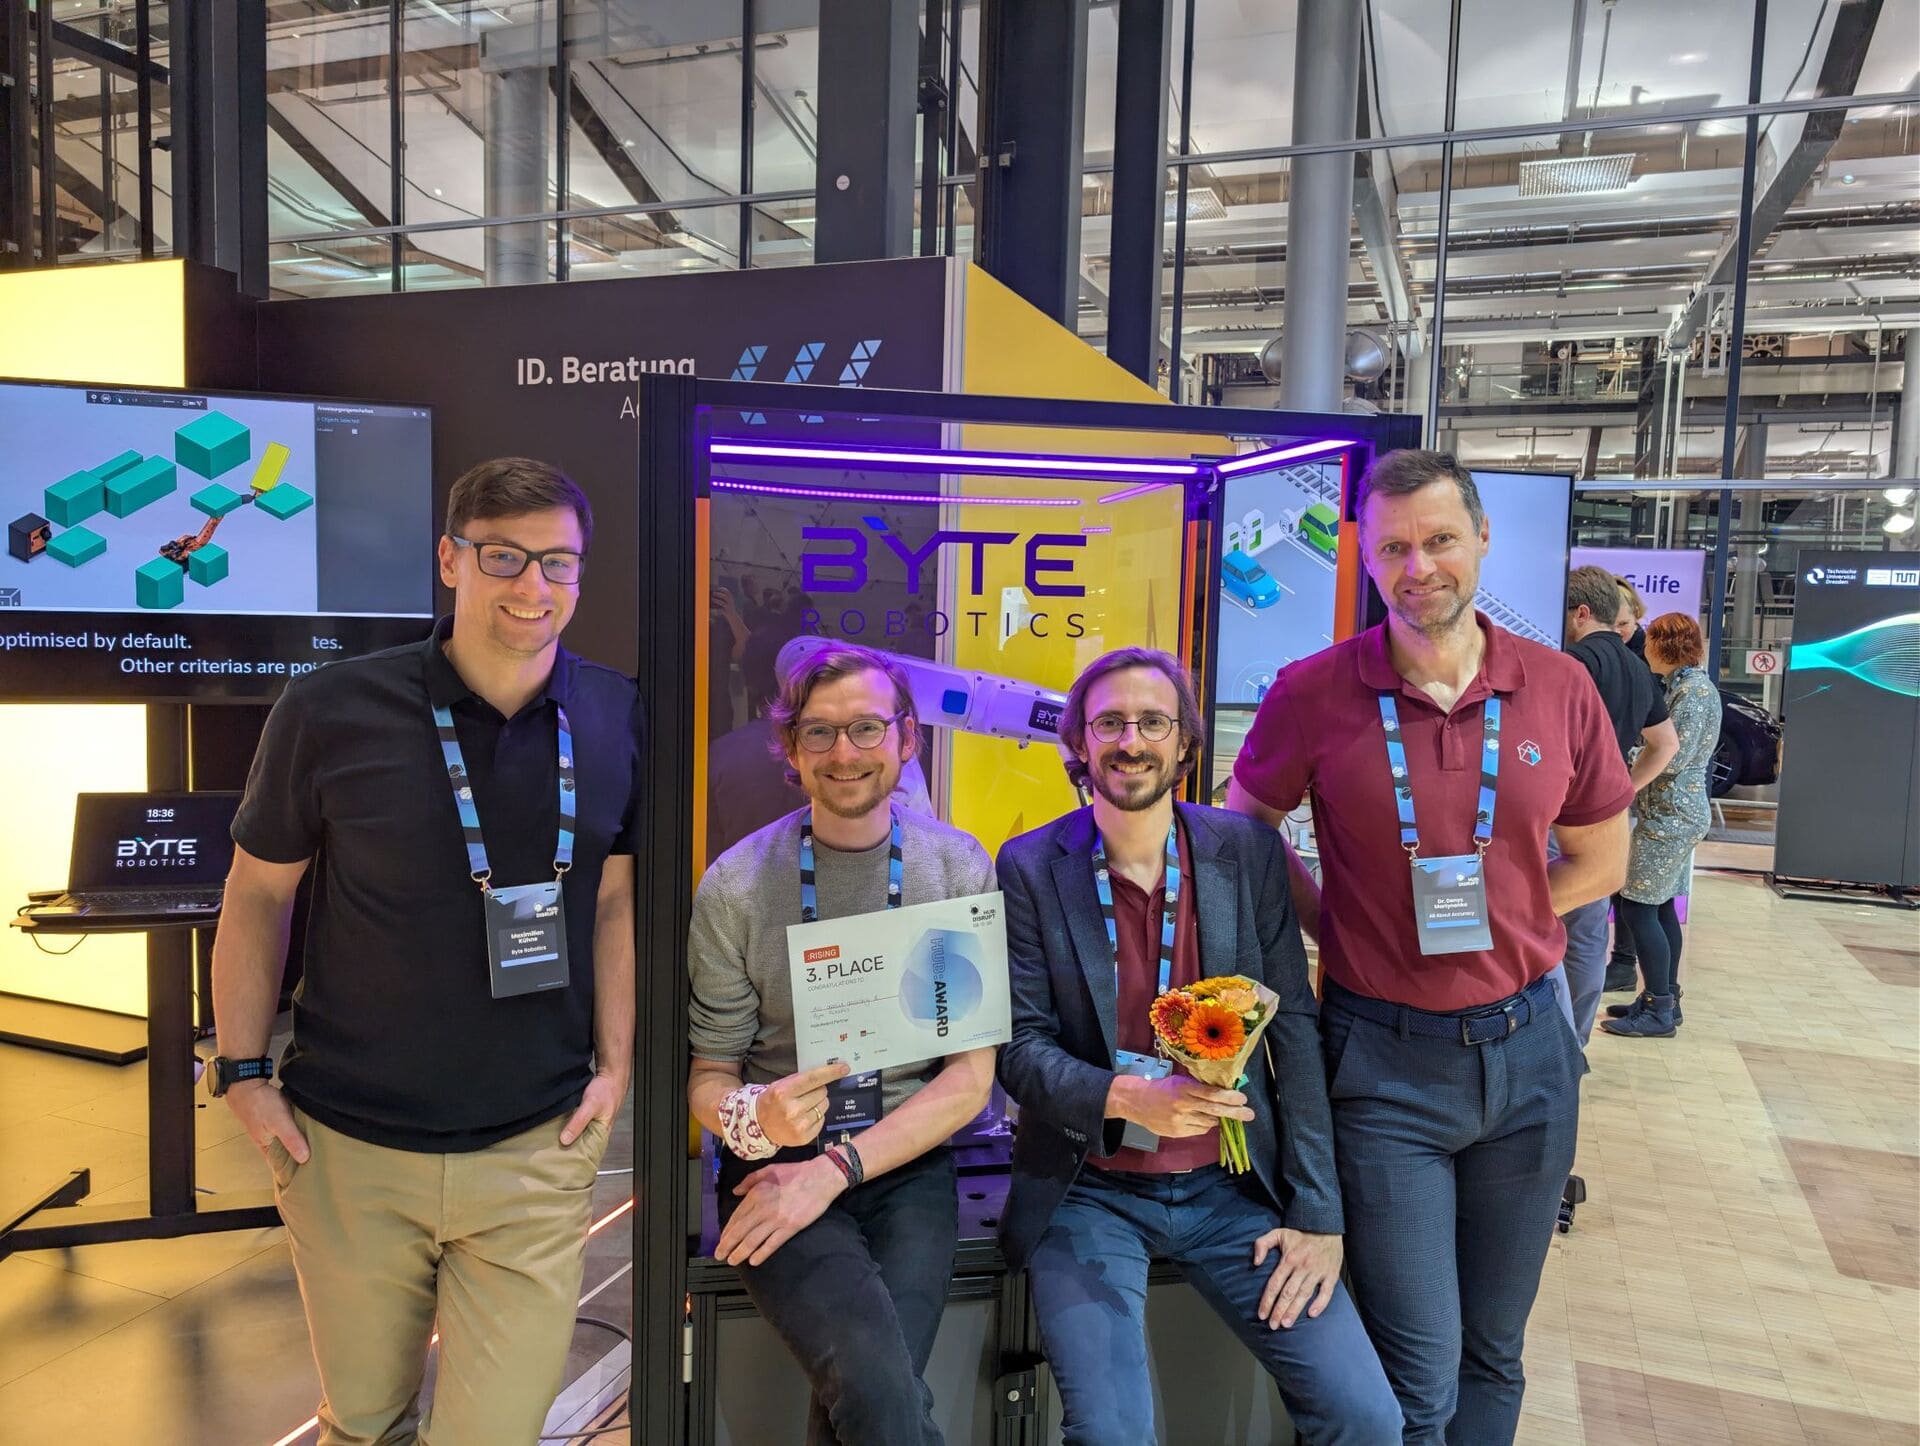
We work closely with automation companies, software providers, and industry partners to bring automated robot programming into real-world applications.
The partnership with byte robotics is crucial to the growth of our company. Working with byte robotics has been a completely smooth and pleasant experience from day one. Together, we’re making progress!
Translated from German
Answers about integration, prerequisites and getting started with byte robotics.
byte robotics generates and optimizes robot motion from a digital task definition. Planning accounts for geometry, robot kinematics and the specified process requirements.
Your team defines the process and reviews the result. Available program formats depend on the integration and target system. Validation on the physical cell remains part of commissioning.
byte robotics adds automated motion planning to your engineering environment. The integrations for Visual Components, KUKA.Sim and iiQWorks.Sim build on your existing simulation and programming workflow.
Planning uses the robot cell, relevant geometry, process positions and constraints. We review the requirements for your software version before you get started.
Our technology is designed to address different robot kinematics and manufacturing tasks that can be described digitally. Suitability depends on the robot model, process requirements, available data and selected integration.
Share your engineering environment, robot model and task with us. Together, we can assess the prerequisites and a suitable starting point. Collision checks depend on the geometry provided and how it is modeled.
The software automates the search for suitable robot motion and its optimization. Your team can evaluate sequences in the virtual environment and regenerate them when requirements change.
The effort saved depends on the task, data quality and existing workflow. A demonstration based on your application helps establish the potential.
byte robotics Headless provides the planning and optimization technology as a software component. Your application supplies the task and robot data, then consumes the generated motion.
We agree on interfaces, data formats, deployment and licensing in the context of your architecture and application. A description of your product and intended workflow is a useful starting point.
Public funding helped us turn research into robust industrial technology. In 2023, the team behind byte robotics, then known as AuRora, won the Automotive cluster of the IQ Innovation Award Central Germany. Two awards in the Startup Competition – Digital Innovations followed in 2025.